The release offers reusable control, planning, vision, simulation, and hardware-integration software under an Apache 2.0 license.
Intrinsic is releasing foundational robotics software that industrial developers may otherwise need to build repeatedly for each automation project. Assembly Magazine reports that Intrinsic Core is available through the company’s GitHub repository.
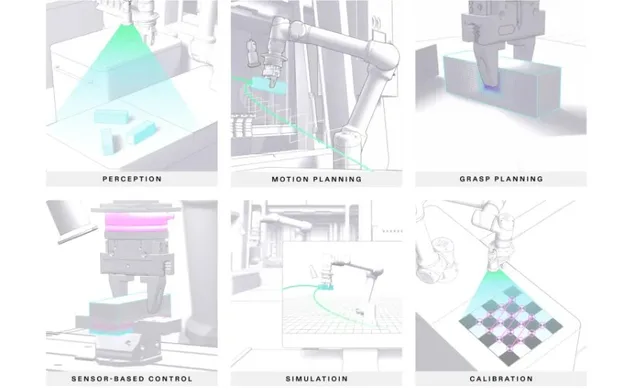
The software is compatible with the Robot Operating System, a common framework for connecting robot components. It includes robot control, motion and grasp planning, machine vision, simulation, and hardware-integration tools under an Apache 2.0 license.
One component, Intrinsic Control, is described as a real-time control framework that uses sensor feedback to adjust a robot’s behavior while it moves. Intrinsic says its design can let developers change robot arms, grippers, or sensors without rewriting hardware drivers.
Other tools can generate collision-free paths, adapt grasps to a part’s position and orientation, and estimate the pose of three-dimensional parts using NVIDIA FoundationPose. According to Intrinsic, that capability could reduce the need for rigid fixtures in some applications.
The package also includes Gazebo-based simulation, automated camera calibration, and preconfigured drivers for supported robots, grippers, and three-dimensional cameras. The available hardware list and documentation will matter to integrators deciding whether the software fits their equipment.
Intrinsic is also releasing an Open Machine Tending Solution as a starting point for CNC machine-tending projects. Assembly Magazine says it can be customized for FANUC and Universal Robots systems.
For plant teams, the practical benefit is a chance to reuse basic software infrastructure during prototyping instead of rebuilding it for every application. Production suitability still depends on integration time, validation, site conditions, and whether the available drivers match equipment already on the floor.