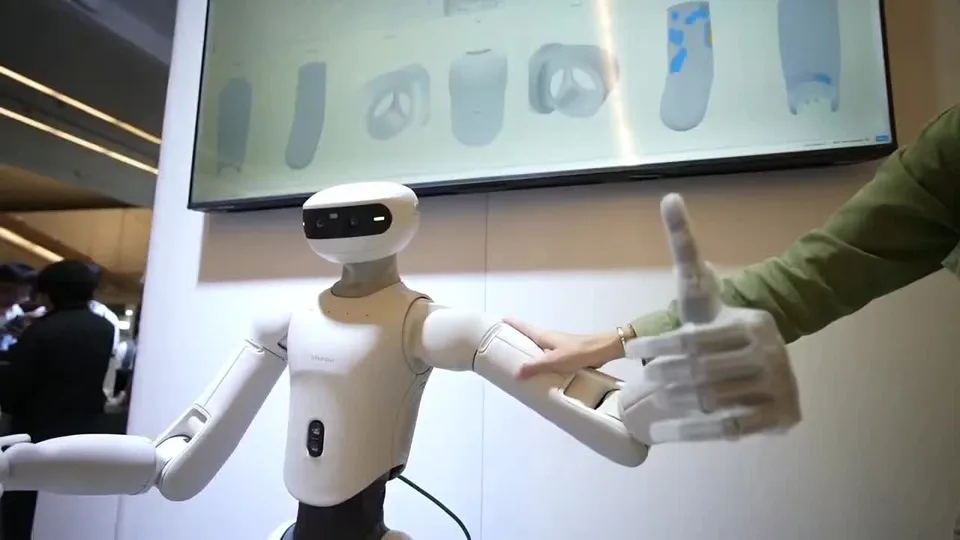
The announced D01, W02 and AE01 form a proposed hardware-and-data loop, demonstrated publicly but not yet shown as scaled deployment.
Sharpa announced three tactile-robotics products at the International Conference on Intelligent Robots and Systems in Pittsburgh on September 28, according to Chinese technology outlet TMTPost.
The D01 is a full-size robot designed to sense contact across its body while handling objects. Sharpa reports a 100-hertz tactile sampling rate and a force-sensing range of 0.1 to 20 newtons. In practical terms, its electronic “skin” is intended to help the robot react when it touches a person, object or surface—not only when its hands make contact.
The W02 is a smaller dexterous hand for tools and objects designed for people. TMTPost reports that it is about 30% smaller than Sharpa’s earlier W01 and weighs under 750 grams. Sensors cover its fingertips and palm, allowing the hand to detect where and how strongly it is touching an object.
The third product, AE01, is an exoskeleton glove for teleoperation. It uses 22 encoders to send an operator’s hand movements to a robot, while five fingertip vibration motors return information about contact. That two-way link could help an operator adjust grip force without relying only on a video feed.
At IROS, TMTPost reported that a bartender wearing AE01 remotely operated D01 to prepare a cocktail. This was a public demonstration, not evidence of broad commercial deployment.
Sharpa did not announce W02’s price or delivery schedule in the cited report. The next practical test is whether customers can buy these systems and reproduce their reported manipulation and teleoperation performance across different workplaces.